DESIGN & APPLICATION PARAMETERS
Engineered for rigorous production cycles.
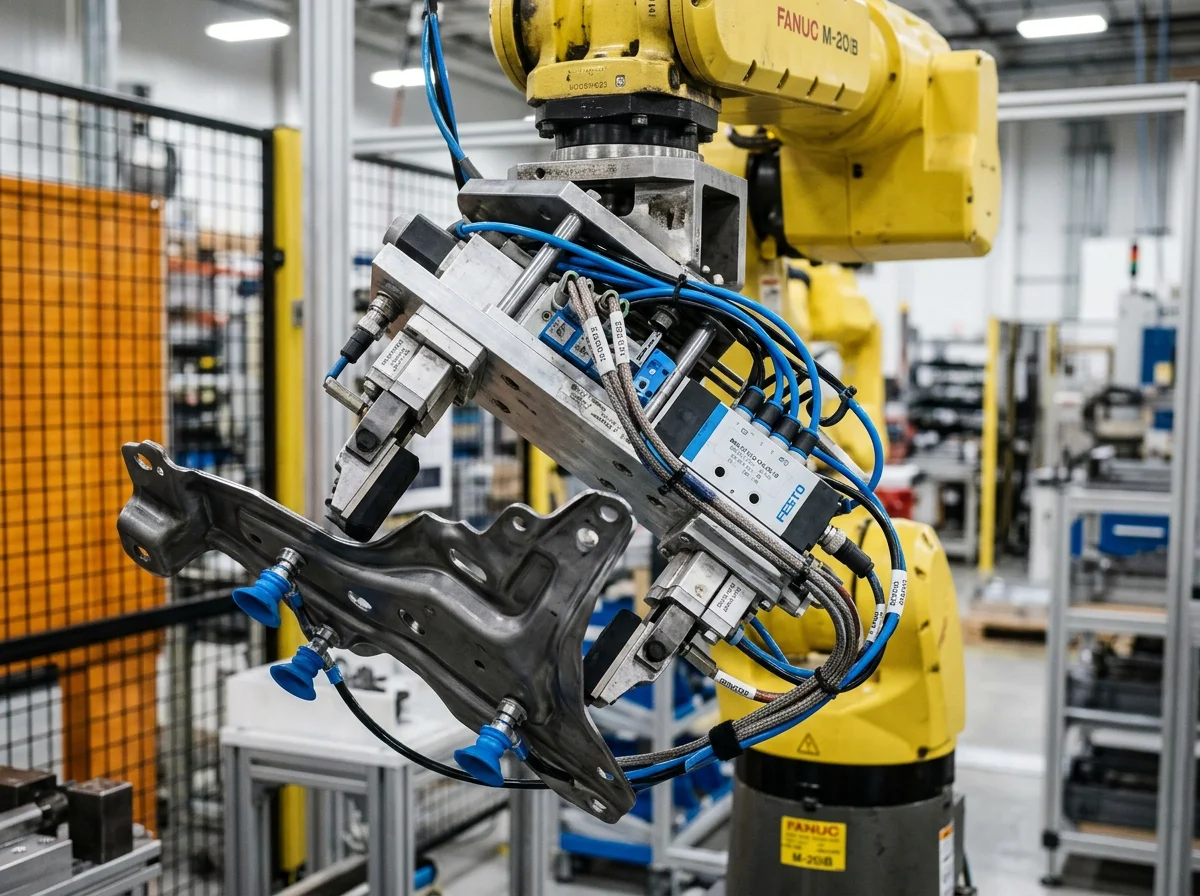
We design and manufacture rugged End-of-Arm Tooling (EOAT) engineered for high-speed material handling, machine tending, and robotic component placement. Each gripper system undergoes rigorous dynamic payload analysis, center-of-gravity calculation, and acceleration stress simulation to ensure robot motor longevity and cycle stability.
Featuring Festo/SMC pneumatic manifolds, multi-jaw mechanical grippers, vacuum suction cups with level compensators, and inductive part-presence sensors, our EOAT solutions provide fail-safe gripping even during emergency stop events.
Typical Industrial Applications
Robotic EOAT
High-Speed Machine Tending
Panel Transfer
Pneumatic Clamping
Multi-Gripper Changing
Request a Custom Engineering Proposal
We customize every system to your component geometry, cycle time targets, and tooling standards.
Consult an Engineer ↗